A Sequential Stalk-Based Manipulation Strategy for Post-Harvest Broccoli Orientation
IEEE Robotics and Automation Letters (RA-L)
Yongkai Ye; Chonglei Sun; Yuchen Liang; Jun Wang; Rob B.N. Scharff; Dongdong Du
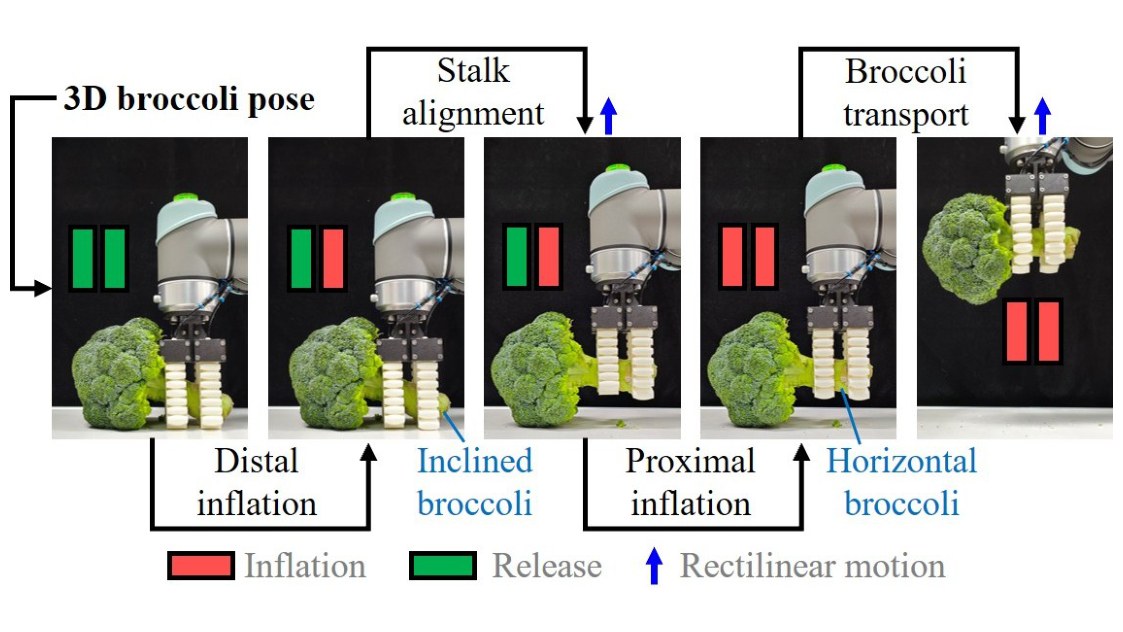
Automating broccoli reorientation after harvest is hard: the head is fragile and irregular, so grasping it directly risks bruising and floret separation. We propose a sequential stalk-based manipulation strategy in which a depth-based 3D pose estimate guides a UR5 arm with a parallel soft pneumatic gripper to grasp the stalk — never the head — and then horizontally align the broccoli through se...