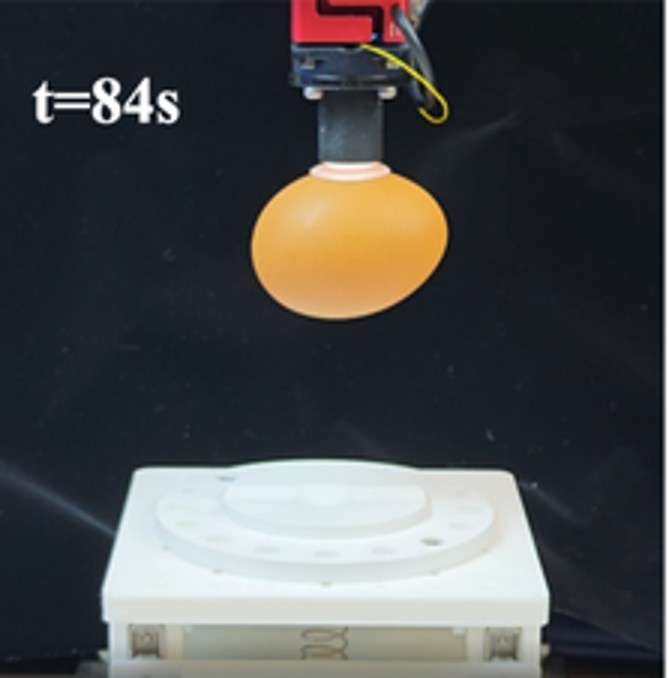
Octopus-Inspired Embodied Tactile Intelligence: A Universally Calibrated Miniature Vision-Based Suction Cup
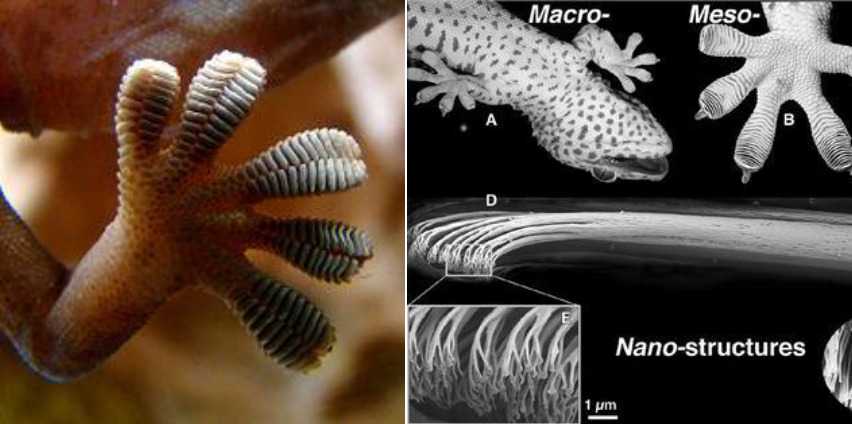
A small suction cup. A sense of touch. Vision-based force and orientation sensing for delicate robotic manipulation.
A small suction cup. A sense of touch. Vision-based force and orientation sensing for delicate robotic manipulation.
Our interactive soft robotic handshake device allowed users to exchange real-time handshakes through a pair of soft robotic hands. The installation engaged visitors, fostering unique connections through robotics and demonstrating the potential of human-machine interaction in social experiences.
I attended Cybathlon 2024 ROB race as an advisor and also helped on designing mechanical part. The race took place in Zurich and aims to help people with limited autonomy when interacting with their physical environment.
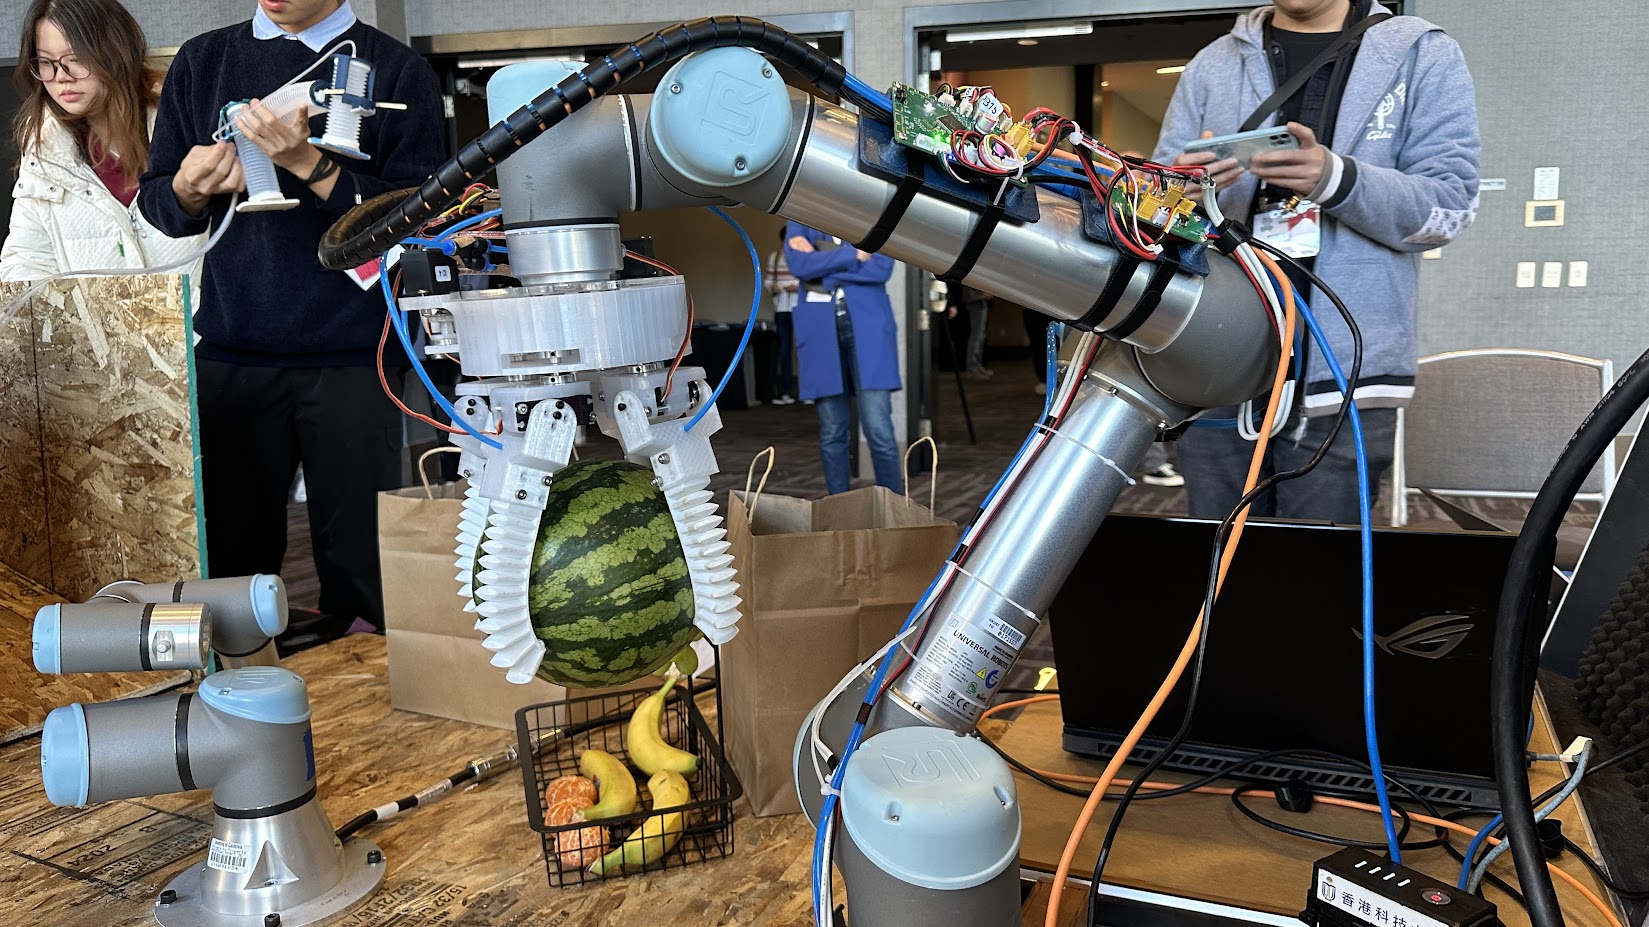
I attended the IEEE RoboSoft Competition 2024 as the leader of the team. Our team built a soft gripper mounted on a UR5 robot arm to automatically grab and manipulate multiple kinds of fruits. We won the autonomous prize in the competition.
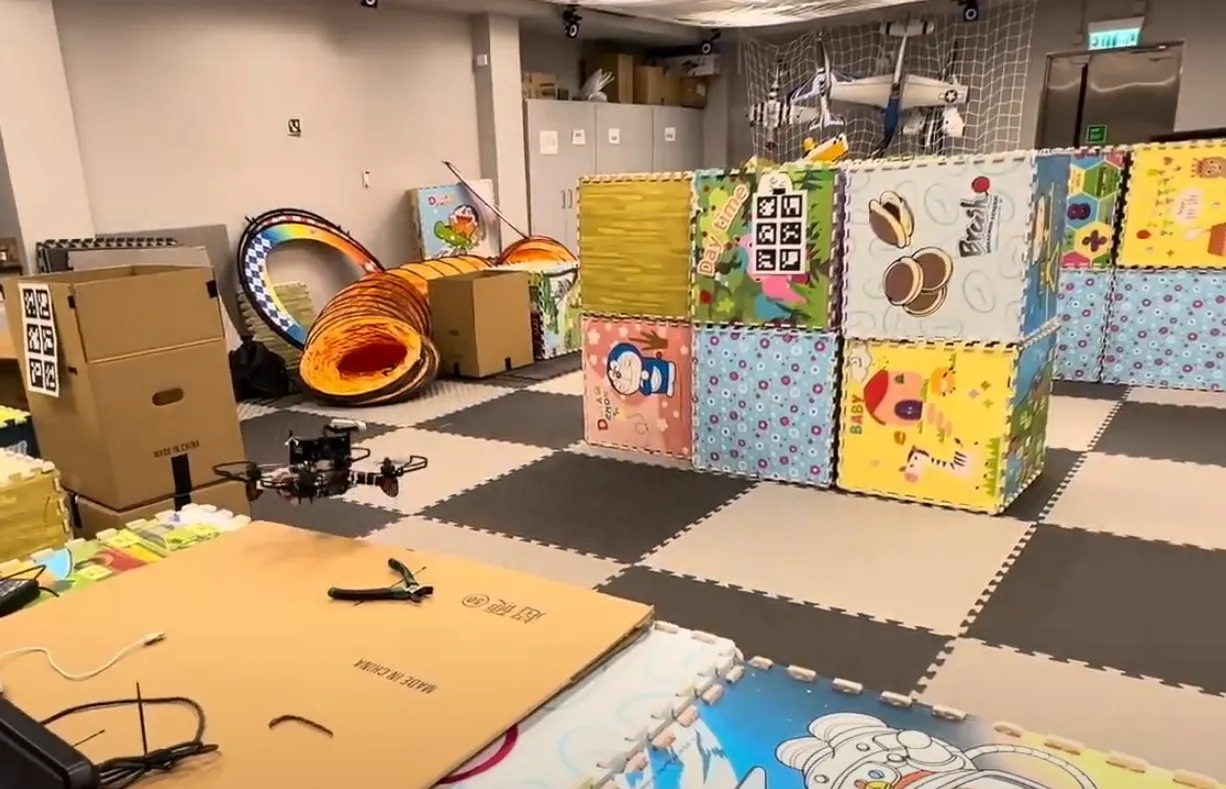
This HKUST PG course gives a comprehensive introduction to aerial robots. The goal of this course is to expose students to relevant mathematical foundations and algorithms, and train them to develop real-time software modules for aerial robotic systems.
This is the 2021-2022 FYP project of ISD. The project identified that while land-movement monitoring solutions in the construction industry are widely used, they remain inconvenient. To address this, we proposed an Intelligent Real-Time Land-movement Monitoring System (IRLMS) with two methods: Smart Inclinometer (SInc) and Meter In a Tube (MIT).
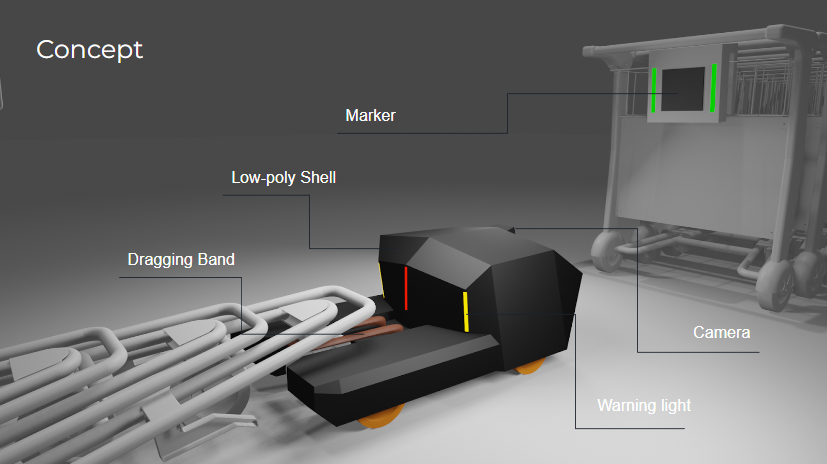
This is the 2020-2021 Year 3 second semester project of ISD. This project worked with Hong Kong International Airport (HKIA). The project vision a fully autonomous trolley hauling system (Trocomotor), since during interviews and shadowing, short of trolley hauling workers was observed.
This is the 2020-2021 Year 3 first semester project of ISD. This project has no industrial partner due to the pandemic. The topic is scoped by the professor which is Personal Mobility. After some interviews and observation of current sharing transportation, the team thinks that the biggest problem of the current system is deployment. Sharing devices is hard to deploy. Therefore a self-driving s...
This is the 2019-2020 Year 2 project of ISD. This project worked with several Hong Kong elderly centers and rehab centers. The topic is scoped by the professor which is Elderly Robotics. After some interviews shadowing and observation with several elders and physical therapist, the team believes that the main obstacle lying in the way for elderly rehab is motivation.
This Undergraduate Research Opportunities Program (UROP) project is named as Robotics Gripper Development for Warehouse Automation. The naming involves Gripper and Automation which means the research focus on developing a gripper mechanism which can be applied to warehouse environment mainly for automation purpose.
I attended RoboMaster Competition representing the HKUST RoboMaster Team (ENTERPRIZE). I was a mechanical team member in 2019 and I was captain in 2020. The team won Grand Prize in International Regional and First Prize in Final Tournament.
During my high school years, I actively participated in the FIRST Robotics Competition (FRC) and FIRST Tech Challenge (FTC). The competition include 2015-2016 FRC season ‘Stronghold’, 2016-2017 FRC season ‘STEAMworks’ and 2015-2016 FTC season ‘Res-Q’, 2016-2017 FTC season ‘Velocity Vortex’.